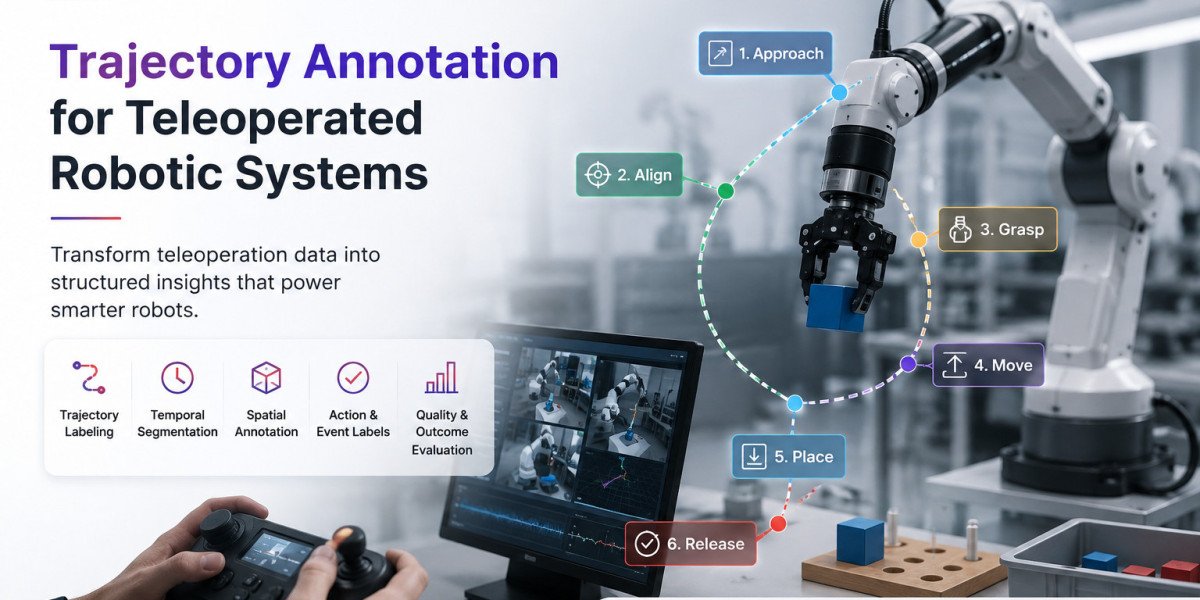

Teleoperated robots rely on human operators to perform tasks that may be too complex, hazardous, or unpredictable for fully autonomous systems. From industrial manipulation and warehouse operations to remote inspection and humanoid robotics, these systems generate valuable demonstrations of how robots should move, react, and complete tasks. However, raw teleoperation data alone is not always sufficient for training advanced robotic models. The movements captured during operation must be structured, interpreted, and labeled so that machine learning systems can understand the relationship between actions, environments, and outcomes.
This is where trajectory annotation for teleoperated robotic systems becomes essential. By converting continuous robot movements into structured training information, trajectory annotation helps developers build models capable of learning manipulation strategies, motion planning, control policies, and task-specific behaviors.
What Is Trajectory Annotation?
A robotic trajectory represents the path a robot takes while performing an action. It can include the position, orientation, velocity, acceleration, joint configurations, gripper states, and other sensor or control information recorded over time.
Trajectory annotation adds meaningful labels and contextual information to these movement sequences. Instead of treating a trajectory as a simple stream of coordinates, annotation can identify important events such as:
Task initiation and completion
Object approach and contact
Grasping and releasing
Changes in movement direction
Waypoints and key poses
Collision or near-collision events
Successful and unsuccessful actions
Human intervention points
Environmental obstacles
Gripper or end-effector states
These annotations create a structured representation of robotic behavior that can be used for supervised learning, imitation learning, reinforcement learning, and policy development.
Why Teleoperation Generates Valuable Training Data
Teleoperation provides an important source of real-world demonstrations because skilled operators can perform actions that are difficult to program manually. An operator may intuitively adjust a robot's movement when an object shifts, an obstacle appears, or a grasp does not initially succeed.
For example, consider a teleoperated robotic arm picking up an irregularly shaped object. The operator may approach the object from a particular angle, slow the robot before contact, adjust the wrist orientation, close the gripper gradually, and reposition the arm if the first grasp is unstable. A raw recording captures these movements, but trajectory annotation helps identify the individual decisions and transitions within the sequence.
This additional structure allows machine learning systems to learn not only what the robot did, but also when and why specific actions occurred.
Key Components of Trajectory Annotation
Effective trajectory annotation typically combines spatial, temporal, and semantic information.
1. Spatial Annotation
Spatial labels describe where the robot and relevant objects are located. Annotators may identify end-effector positions, joint configurations, object locations, obstacles, and interaction zones.
For manipulation tasks, 3D positions and orientations can be especially important because small changes in approach angle or wrist orientation can influence whether a grasp succeeds.
2. Temporal Annotation
Robotic behavior unfolds over time, making temporal segmentation a critical part of annotation. A long demonstration can be divided into meaningful phases such as approach, alignment, grasp, transport, placement, and release.
Temporal boundaries help learning algorithms distinguish individual actions within a continuous trajectory.
3. Action and Event Labels
Annotators can assign semantic labels to key events. These may include “approach object,” “grasp,” “lift,” “rotate,” “place,” or “release.”
Failure events can also be captured. For instance, an unsuccessful grasp, object slip, unexpected obstacle, or corrective movement may provide valuable information for improving robotic policies.
4. Quality and Outcome Labels
Trajectory data becomes more useful when annotations indicate whether a demonstrated behavior was successful. Quality labels can distinguish smooth and efficient trajectories from those involving unnecessary movements, collisions, or repeated corrections.
These labels allow developers to identify high-quality demonstrations and understand the characteristics associated with successful task completion.
The Role of Trajectory Annotation in Physical AI
Physical AI systems must operate in the real world, where actions have physical consequences. Unlike conventional AI systems that primarily process digital information, robots must perceive environments and translate decisions into coordinated physical movements.
High-quality Physical AI training data therefore needs to represent both perception and action. Trajectory annotations provide the action-side context required to connect visual observations with robotic behavior.
For example, a training sample might associate a camera observation of a cup with the robot trajectory used to approach, grasp, lift, and move the cup. When repeated across different environments, object types, lighting conditions, and operator strategies, these examples can help models learn more generalizable policies.
Challenges in Annotating Teleoperated Trajectories
Trajectory annotation presents several challenges. Robotic motion is continuous, and determining exactly where one action ends and another begins can require domain expertise. Operators may also use different strategies to complete the same task, resulting in trajectories that vary substantially while achieving the same outcome.
Another challenge is multimodal synchronization. Teleoperated systems can produce data from RGB cameras, depth sensors, LiDAR, force-torque sensors, joint encoders, controllers, and other devices. These streams must be aligned accurately with the trajectory and corresponding annotations.
There is also the challenge of edge cases. Sudden object movement, occlusion, sensor noise, unstable grasps, and operator corrections can create unusual trajectory patterns. Excluding these examples may reduce dataset diversity, while poorly labeled edge cases can introduce noise into the training process.
Best Practices for High-Quality Trajectory Annotation
A reliable annotation workflow should begin with a clearly defined ontology. Teams should establish consistent labels for actions, events, task phases, failure conditions, and trajectory quality before annotation begins.
Temporal precision is equally important. Key events should be timestamped consistently so that annotations correspond accurately with sensor observations and robot states.
Quality control should include multiple levels of review. Automated validation can detect missing timestamps, inconsistent labels, or abnormal trajectories, while expert review can assess whether annotations correctly represent robotic behavior.
It is also valuable to preserve unsuccessful demonstrations rather than removing them automatically. Failure trajectories can help models learn what to avoid and support the development of more robust control policies.
How Annotera Supports Robotic Trajectory Annotation
At Annotera, we understand that teleoperated demonstrations can become significantly more valuable when they are transformed into structured, machine-learning-ready datasets. Our robotics data annotation services can support trajectory labeling workflows involving robotic manipulation, task segmentation, action recognition, spatial relationships, and multimodal sensor data.
A carefully designed annotation pipeline can help organizations organize demonstrations according to task stages, identify critical motion events, distinguish successful and unsuccessful behaviors, and create consistent datasets for model development.
The objective is not simply to label robot movements. It is to preserve the relationship between perception, action, timing, and outcome so that robotic learning systems can extract meaningful behavioral patterns from demonstrations.
Conclusion
Trajectory annotation is an important bridge between human expertise and robotic intelligence. Teleoperators provide valuable demonstrations of how robots can navigate physical tasks, but structured annotation makes those demonstrations easier for machine learning systems to interpret.
By capturing spatial movements, temporal phases, interaction events, failures, and outcomes, trajectory annotation can contribute to more capable robotic policies and more effective Physical AI systems. As teleoperation becomes increasingly important for collecting real-world demonstrations, high-quality annotated trajectories will play a central role in developing robots that can learn complex skills and perform them reliably.
For organizations building next-generation robotic systems, investing in accurate, consistent, and scalable trajectory annotation is therefore more than a data preparation step—it is an essential part of transforming human demonstrations into actionable intelligence.